
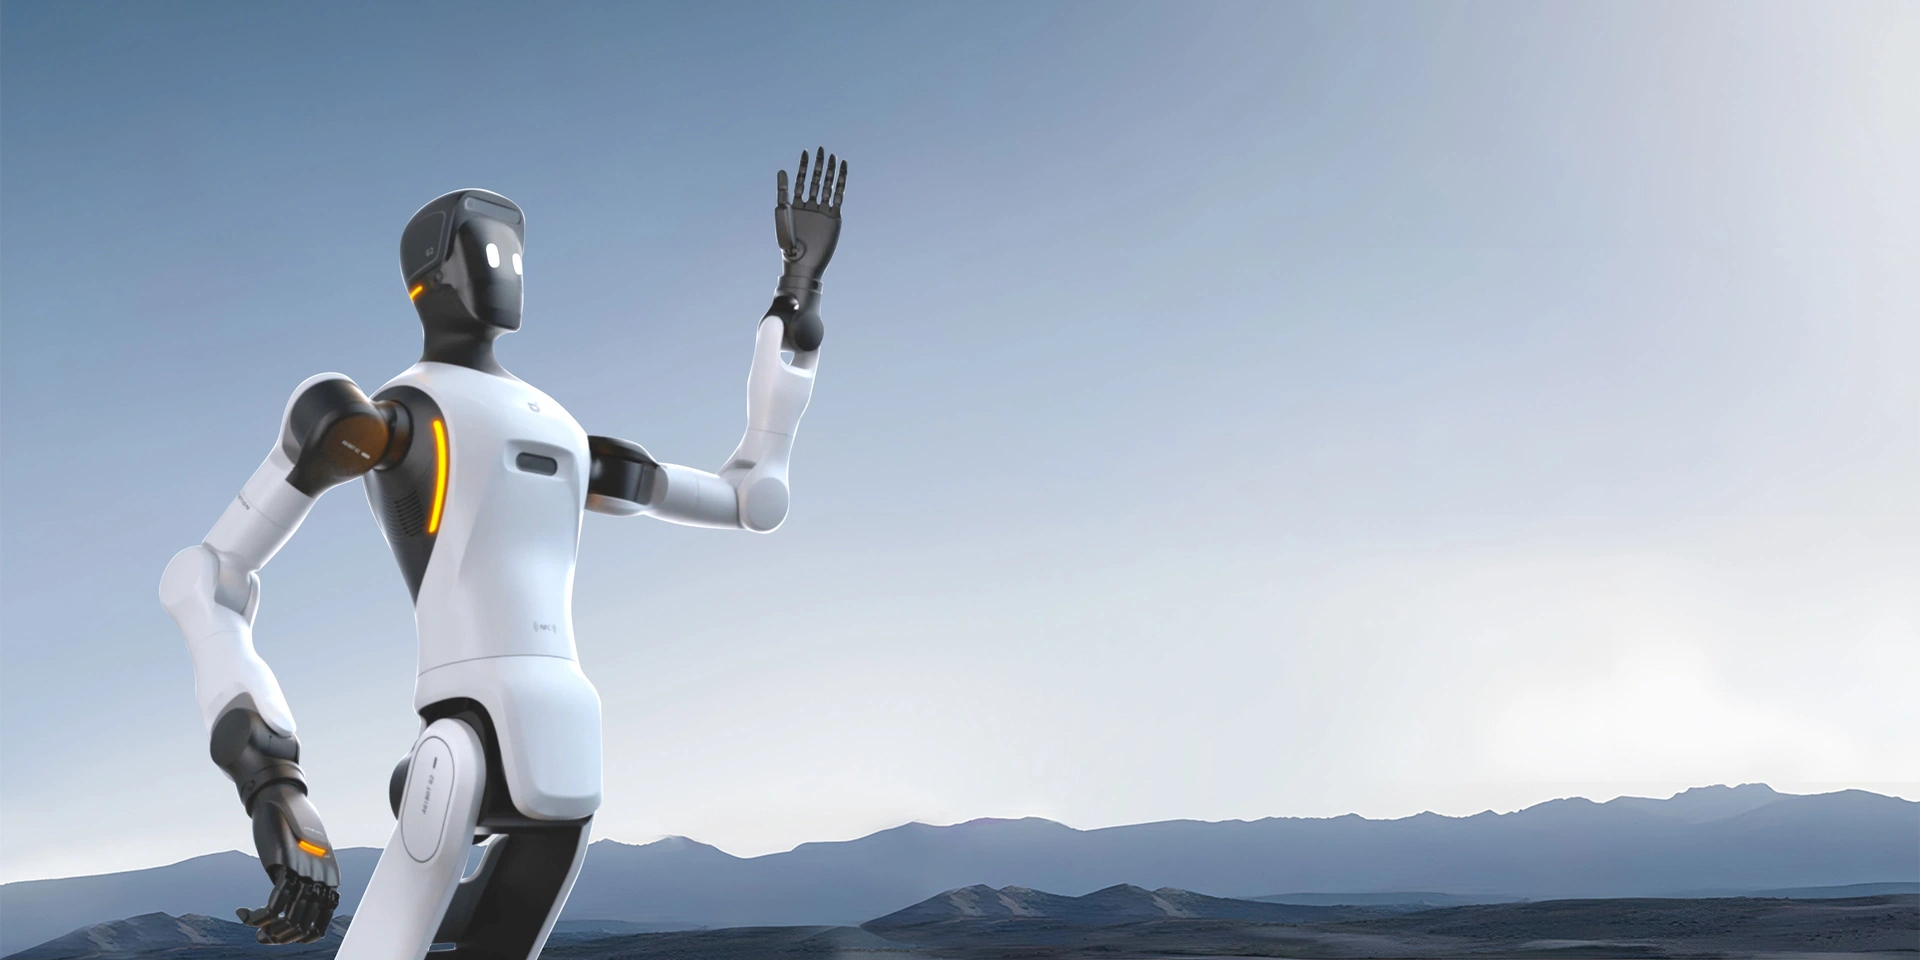
Why does G2's force-controlled manipulation need contact-level benchmarks?
AGIBOT presents G2 for physical interaction in industrial work with force control and embodied-AI software. During insertion or polishing, the controller must regulate tool force and position despite friction and small surface differences. Arm strength alone cannot establish that a robot can avoid damaging a delicate part. Model versions and hand sensors matter because they change what the controller can observe after first contact.