
All humanoid robots
Wheeled humanoidNot confirmed

AgiBot A2-W

A
AgiBot

China · Reviewed 2026-09-20

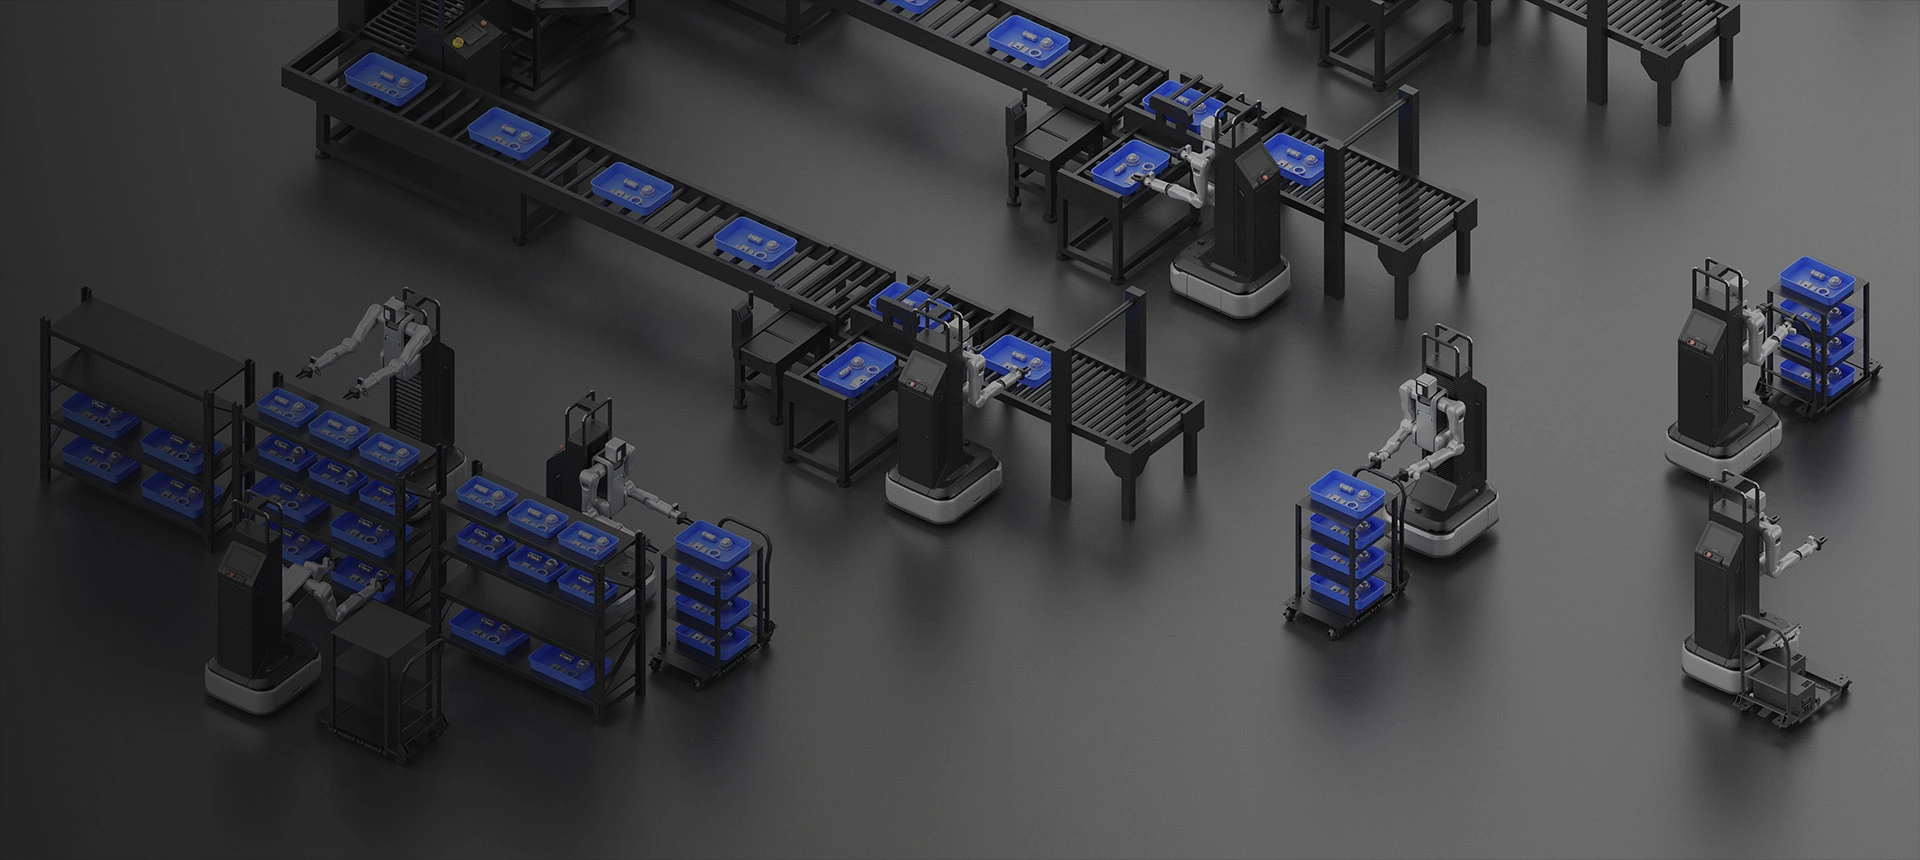
A2-W places AGIBOT’s dual-arm manipulation system on a wheeled base for manufacturing and material-handling applications.

Published offer

Price not verified

Availability: Not confirmed

AGIBOT A2-W official manufacturer product image

01 / At a glance

Understanding AgiBot A2-W

Height
163 cm
Weight
230 kg
DoF / joints
22

Intended applications

Picking, placing, transport and manufacturing research

02 / Hardware profile

AgiBot A2-W specifications

Category
Wheeled humanoid
Commercial status
Listed by manufacturer
Availability
Not confirmed
Country of origin
China
Height
163 cm
Weight
230 kg
Degrees of freedom
22
Use cases
Picking, placing, transport and manufacturing research

03 / Pricing and purchasing

Published offers and availability

No numerical offer recorded

Contact AgiBot for a written quotation for the exact configuration, including delivery, support and any software access fees.

04 / Technical analysis

AgiBot A2-W engineering analysis

What tasks fit A2-W's wheeled dual-arm arrangement?

A2-W puts a manipulation torso on a mobile wheeled base. This can be useful when workstations are on one level, provided the robot has clearance for its body and carried parts. The base's navigation and arm control must exchange precise position information; a small docking error can place a gripper outside its expected work envelope. Published manipulation footage may involve human-prepared objects or external guidance.

Configuration and hardware details

01

Moving the workspace with the arms

The manufacturer specifies seven joints per arm and a working height extending from floor level to about two metres. Its omnidirectional chassis supports sideways movement and turning within a confined workspace.

02

What to check before comparing

AGIBOT lists a 5 kg load for each arm. This is an arm specification, not a statement that the robot can safely handle every 10 kg object with both hands. Reach, grasp geometry and motion still need to be checked for the intended task.

03

Why the A2-W base changes the factory acceptance test

A2-W uses a wheeled base to move its dual arms around a workstation. A bipedal stair-climbing comparison would be misleading: the relevant geometry is the combined reach of the mobile base, torso and end effector while the platform is parked or moving. A bin may be within arm reach only when the base stops at a repeatable pose, so docking and manipulation errors must be measured together.

Before selecting A2-W for material transport, request the rated tool payload at the working reach, floor and threshold requirements, stopping accuracy and interfaces to conveyors or fixtures. The manufacturer product entry does not itself report repeated customer-site cycle times. A useful report would give successful handoffs per shift, failed alignments and the fraction of operations that required a human correction.

Specification notes

The 2 kWh battery and five-hour runtime are manufacturer specifications. Runtime conditions are not established here.

Hands-on technical guide

AgiBot A2-W: ordering, setup and first controlled test

Commissioning checklist; examples have not been tested on physical hardware by TechniaHQService.

What to order and verify
Catalog access: Not confirmed. Request a written quote or order confirmation from AgiBot for AgiBot A2-W with hardware revision, charger, controller, supported accessories, import/shipping costs, warranty, software entitlement and training. Do not treat a price listing as a delivery guarantee.
Software and equipment
Obtain the model-specific operator manual, controller application, firmware compatibility matrix and developer package from AgiBot. No public installer or SDK is confirmed in this model's catalog record.

AgiBot A2-W workflow

  1. 01Order / accessAgiBot A2-W
  2. 02SoftwareManufacturer-approved package
  3. 03Initial checkRead-only diagnostics
  4. 04Acceptance testSupervised exercise
Conceptual workflow for the exercise below. This is an explanatory diagram, not an electrical wiring schematic or proprietary controller blueprint.

Step-by-step setup and first exercise

  1. 01

    Get the unit and files

    Use the manufacturer's sales or partner channel to confirm the serial configuration, supported software and contents of the delivery.

  2. 02

    Install the approved software

    Obtain the model-specific operator manual, controller application, firmware compatibility matrix and developer package from AgiBot. No public installer or SDK is confirmed in this model's catalog record. Install on the supported host OS and verify the release/build number. Do not use packages intended for another robot.

  3. 03

    Startup and stop check

    Follow the supplied power-on order; inspect battery, joints, cables and controller warnings. Verify the approved emergency stop and initial posture before allowing motion. Keep the test space clear.

  4. 04

    First exercise

    Use a stationary pick-and-place task first, then a separate wheeled approach test with the gripper empty.

  5. 05

    Firmware and software updates

    Compare the current serial/model, controller and firmware versions against the manufacturer's release notes. Export configuration and logs and check recovery options. Obtain the correct signed package or managed update; use the specified power and network conditions. Test stop controls and the same acceptance exercise after updating. If no authorized firmware path exists, do not flash the robot.

  6. 06

    Walking, running and dancing

    Use the approved base-control or gesture interface. Biped walking and running do not apply to a stationary or wheeled platform; do not assume unsupported dance or gesture presets.

Troubleshooting

Controller cannot establish a connection
Verify the host OS, firmware compatibility, authorized account and network setup using the exact delivered manual; do not bypass safety or authentication.
Motion differs from the acceptance exercise
Stop using the approved control, record the exact fault and verify actuator/joint configuration and software revision before repeating.

Capabilities and limits

The acceptance exercise is a proposed commissioning check, not a measured performance result or proof of support for custom locomotion.

05 / Comparable models

Compare AgiBot A2-W with similar robots

Catalog records with their original source dates
FieldAgiBot A2-WGalaxea Dynamics R1Galaxea Dynamics R1 Pro
Height163 cm170 cm170 cm
Mass230 kgNot disclosed in the retained sourcesNot disclosed in the retained sources
Recorded degrees of freedom222426
Source date in record2026-09-202026-09-202026-09-20
Product sourceAgiBot A2-W documentationGalaxea Dynamics R1 documentationGalaxea Dynamics R1 Pro documentation

AgiBot A2-W is recorded as 7 cm shorter than Galaxea Dynamics R1.

AgiBot A2-W is recorded as 7 cm shorter than Galaxea Dynamics R1 Pro.

Community ratings

AgiBot A2-W Reviews & Ratings

Hands-on community feedback is moderated before publication. Technical sub-ratings are optional.

—

0.0(0 reviews)
5 star
0%
4 star
0%
3 star
0%
2 star
0%
1 star
0%

Published reviews

0 total

No published reviews yet

Be the first to submit hands-on feedback for moderation.

06 / References

AgiBot A2-W sources

Manufacturer descriptions and the cited specifications were checked on 20 September 2026. This profile does not report an independent hands-on test.

  • AgiBot official product source (manufacturer)
  • Official manufacturer image (manufacturer)

Continue browsing

Related humanoid robots

All models