
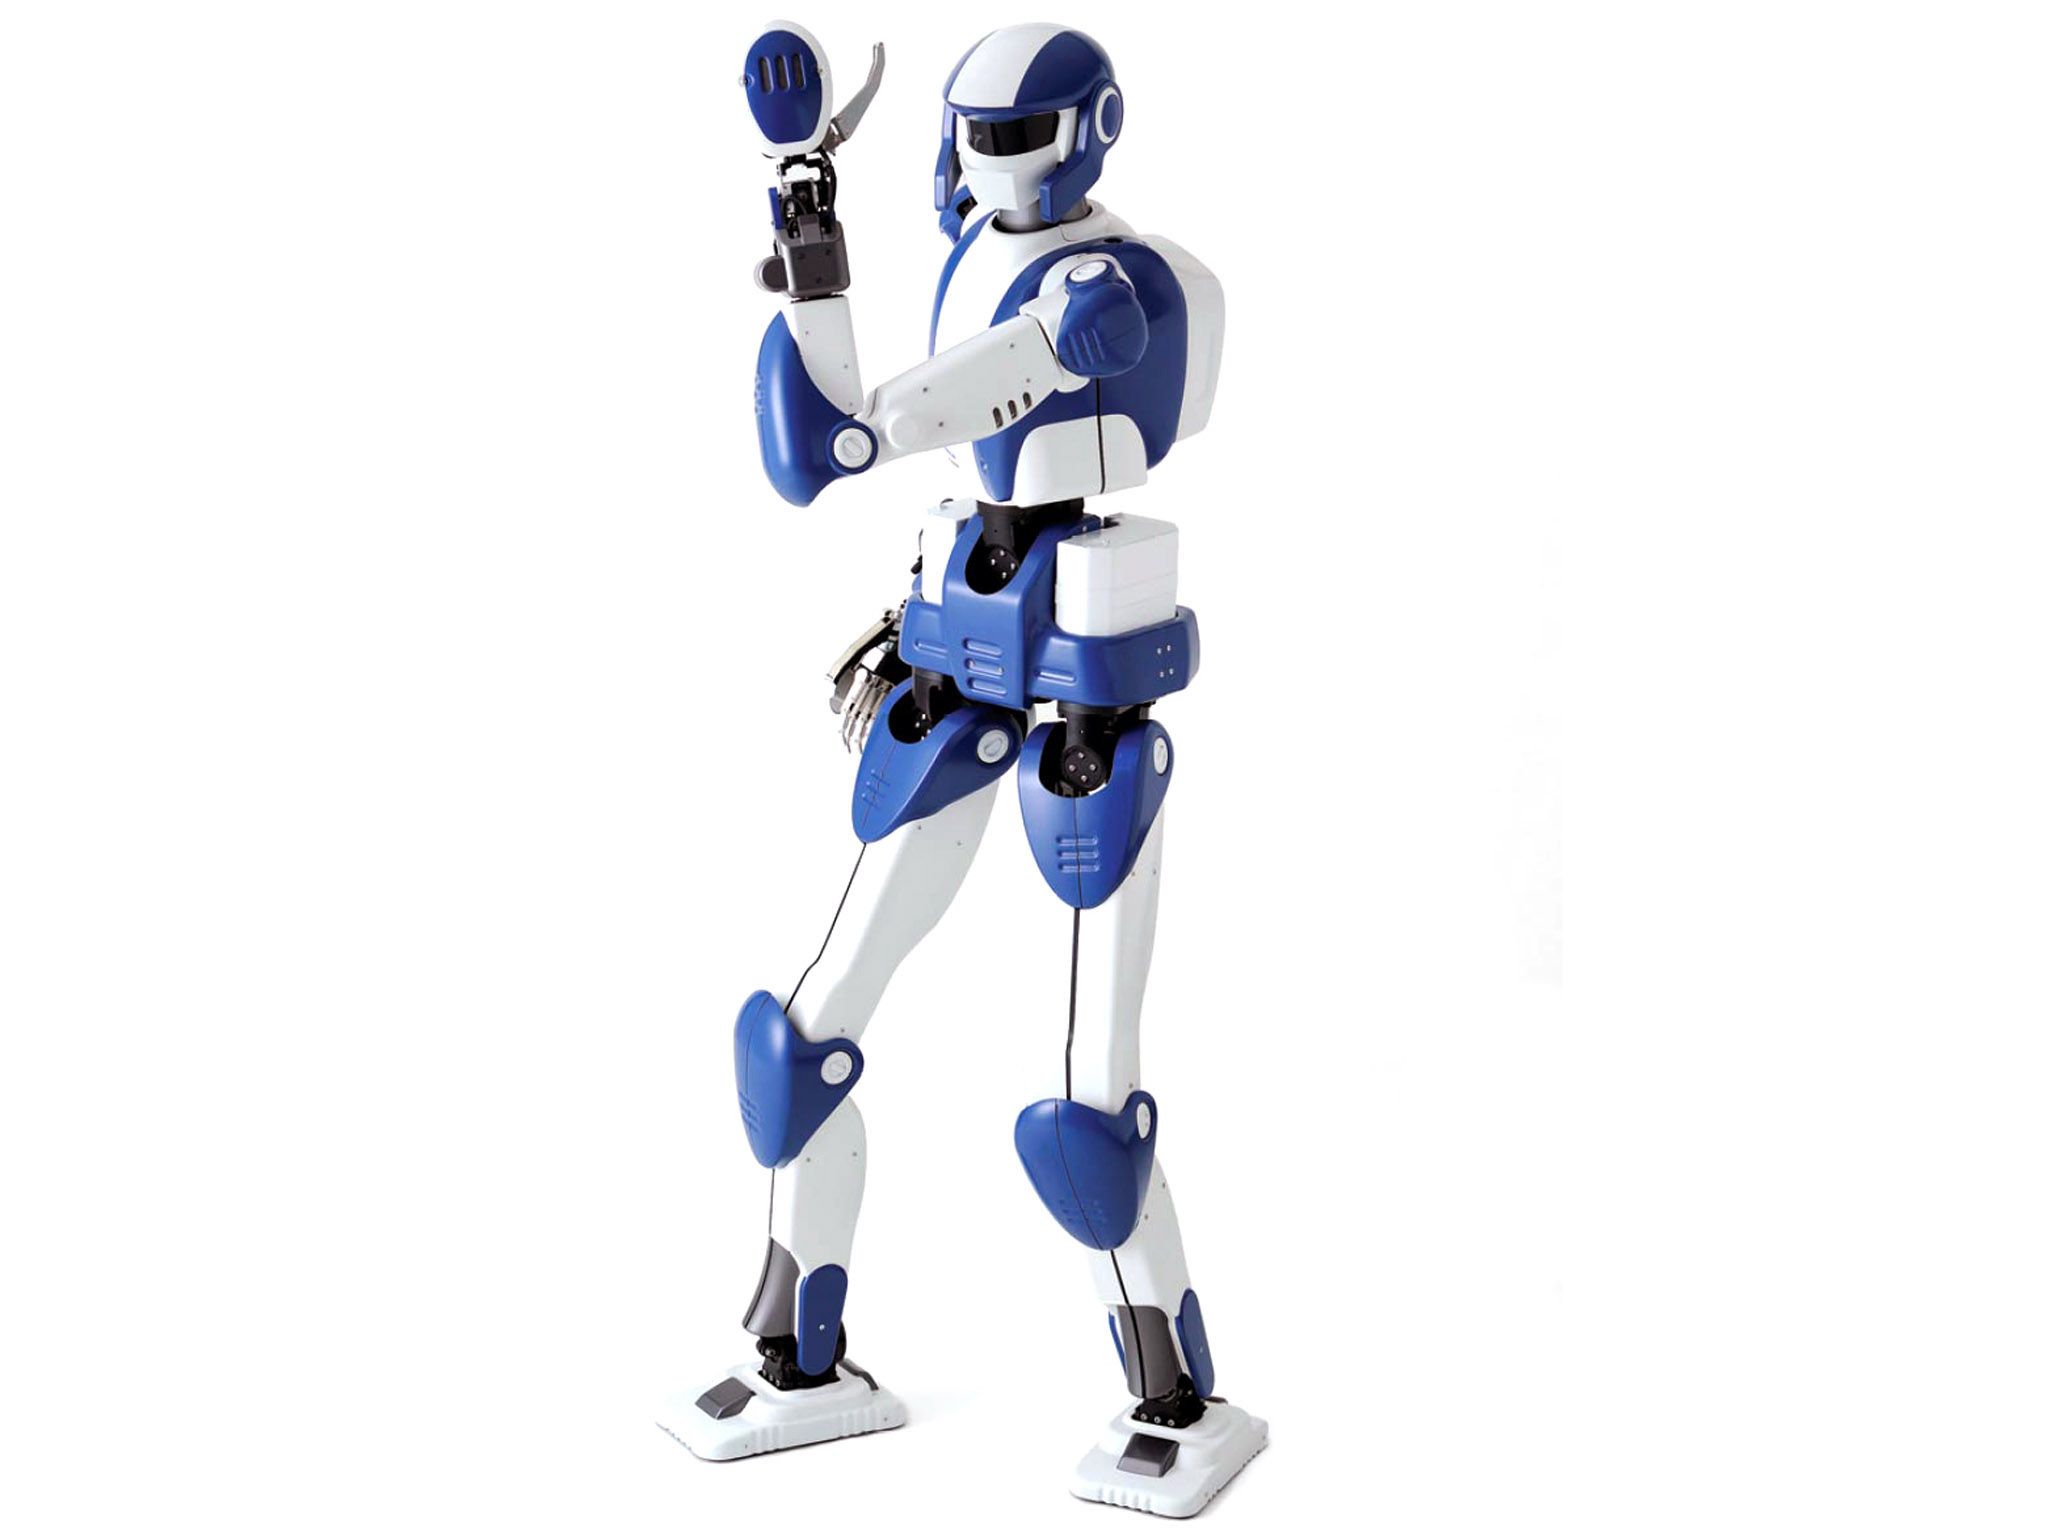
How does HRP-4's lightweight body affect research with human-sized tools?
AIST and Kawada designed HRP-4 for anthropomorphic research, with geometry that permits studies of handling tasks in human environments. Light structural design can help locomotion but it places constraints on payload, joint torque and the stiffness required for precise tool contact. The year of the AIST publication matters: hardware interfaces and supported software from the original 2010 research program may be difficult to maintain in a current laboratory.